RPM to Radians Per Second: The Ultimate Conversion Guide
Master the rpm to radians per second conversion. Get the exact formula, avoid rounding errors, understand the calculus, and use our free calculator.
Read articleInstant conversion for 13 RPM to rad/s (1.361357 rad/s). Analytical π/30 formula, rotational frequency in Hz, and full kinematics.
Generic web calculators use the rounded 0.10472 multiplier. At this rotational speed, that approximation introduces numerical drift:
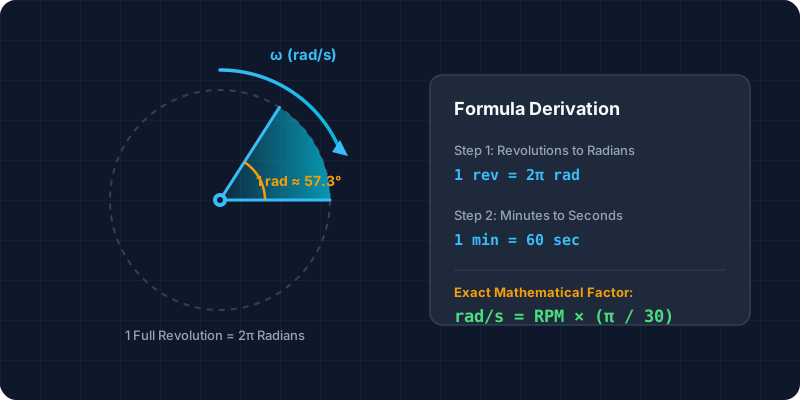
To convert revolutions per minute (RPM) to SI angular velocity (rad/s), multiply by 2π radians per revolution and divide by 60 seconds per minute. The analytical factor simplifies to π/30.
rad/s = 13 × (π / 30) = 1.361357 rad/s
Exact fraction: 13π/30 rad/s · Reciprocal: 1.361 rad/s × (30/π) = 13 RPM
Reverse Conversion: 1.361 rad/s to RPM
Need to convert from radians per second back to RPM? Use our reverse programmatic converter with exact 30/π precision.
Complete dimensional derivation and multi-step conversion method
ω = RPM × (π / 30) rad/sChoose the rotational speed unit you want to convert from:
Choose your starting unit: Revolutions Per Minute (RPM), Radians Per Second (rad/s), Frequency in Hertz (Hz, rev/s), or Degrees Per Second (°/s). The converter dynamically adapts in real time.
Enter your numeric speed value or pick a machinery benchmark. If you are analyzing a rotating rotor, shaft, pulley, wheel, or centrifuge, specify the radius in meters to instantly calculate linear tangential surface speed (m/s, km/h, mph).
Review instant results across all rotational metrics: exact rad/s, RPM, cycle period per revolution, rotational frequency, and peripheral linear speed.
Quick Answer: To convert RPM (revolutions per minute) to rad/s (radians per second), multiply by π and divide by 30 (or multiply by approximately 0.1047197551): ω = RPM × (π / 30) rad/s To convert radians per second (rad/s) back to RPM, multiply by 30 and divide by π (or multiply by approximately 9.5492965855): RPM = ω × (30 / π) Mathematical Derivation From First Principles: 1. One complete revolution equals 360 degrees, which is exactly 2π radians (~6.2831853 rad). 2. One minute equals exactly 60 seconds. 3. Multiplying RPM by 2π radians per revolution and dividing by 60 seconds per minute gives: ω = RPM × (2π / 60) rad/s. 4. Simplifying 2π/60 by dividing numerator and denominator by 2 yields the exact analytical conversion factor: ω = RPM × (π / 30) rad/s. Notations, Common Synonyms & Unit Variations: Rotational velocity is expressed across literature in multiple equivalent notations: • Revolutions per minute: RPM, rev/min, rev per min, rev min, or r/min. • Radians per second: rad/s, rad/sec, rad sec, rads, or rad per second. All of these notations describe the same quantities, so the same π/30 factor applies to each. Practical Engineering Guidance: Avoid using rounded decimals like 0.10472 in multi-stage engineering code. In gear trains, electric motor torque estimations (P = τ·ω), and torsional vibration models, using truncated constants causes cumulative floating-point error. Retaining the symbolic fraction π/30 guarantees exact scientific precision.
RPM to rad/s:
  ω (rad/s) = RPM × 2π ÷ 60
            = RPM × π/30 ≈ RPM × 0.1047197551

rad/s to RPM:
  RPM       = ω × 60 ÷ 2π
            = ω × 30/π ≈ ω × 9.5492965855

Related Rotational Relationships:
  Frequency f (Hz)            = RPM ÷ 60 = ω ÷ 2π
  Degrees per Second (°/s)    = rad/s × 180/π = RPM × 6
  Period T (s/rev)            = 60 ÷ RPM = 2π ÷ ω
Tangential Velocity v (m/s) = ω × r = (RPM × π ÷ 30) × rWorked Step-by-Step Examples: Example 1: Convert 1,800 RPM (standard 4-pole synchronous motor) to rad/s: ω = 1,800 × π / 30 = 60π ≈ 188.49556 rad/s. Frequency: f = 1,800 / 60 = 30 Hz. Period: T = 60 / 1,800 ≈ 0.0333 seconds per rev. Example 2: Convert 100 rad/s to RPM: RPM = 100 × 30 / π = 3,000 / π ≈ 954.93 RPM. Example 3: Tangential linear speed of a 0.25 m radius flywheel at 3,000 RPM: ω = 3,000 × π / 30 = 100π ≈ 314.159 rad/s. v = ω × r = 314.159 rad/s × 0.25 m = 78.54 m/s (282.74 km/h or 175.69 mph).
| Engineering Scenario | Calculation | Kinematic Result |
|---|---|---|
| Automotive Engine — 3,000 RPM → rad/s | 3,000 × π/30 | 314.159265 rad/s · 50 Hz · 18,000 °/s · 0.02 s/rev |
| AC Induction Motor — 1,800 RPM → rad/s | 1,800 × π/30 = 60π | 188.495559 rad/s · 30 Hz · 10,800 °/s · 0.0333 s/rev |
| Industrial Motor — 1,500 RPM → rad/s | 1,500 × π/30 = 50π | 157.079633 rad/s · 25 Hz · 9,000 °/s · 0.04 s/rev |
| Enterprise Hard Drive — 7,200 RPM → rad/s + Hz | 7,200 × π/30 = 240π | 753.982237 rad/s · 120 Hz · 43,200 °/s · 0.00833 s/rev |
| Angle Grinder — 11,000 RPM → rad/s | 11,000 × π/30 | 1,151.917306 rad/s · 183.33 Hz · 66,000 °/s |
| Reverse Conversion — 100 rad/s → RPM | 100 × 30/π | 954.929659 RPM · 15.915 Hz · 5,729.578 °/s |
| RPM | rad/s | Hz | °/s | Period (s) |
|---|---|---|---|---|
| 1 | 0.10472 | 0.0167 | 6 | 60 |
| 2 | 0.20944 | 0.0333 | 12 | 30 |
| 3 | 0.31416 | 0.05 | 18 | 20 |
| 4 | 0.41888 | 0.0667 | 24 | 15 |
| 5 | 0.52360 | 0.0833 | 30 | 12 |
| 6 | 0.62832 | 0.1 | 36 | 10 |
| 7 | 0.73304 | 0.1167 | 42 | 8.5714 |
| 8 | 0.83776 | 0.1333 | 48 | 7.5 |
| 9 | 0.94248 | 0.15 | 54 | 6.6667 |
| 10 | 1.04720 | 0.1667 | 60 | 6 |
| 11 | 1.15192 | 0.1833 | 66 | 5.4545 |
| 12 | 1.25664 | 0.2 | 72 | 5 |
| 13 | 1.36136 | 0.2167 | 78 | 4.6154 |
| 14 | 1.46608 | 0.2333 | 84 | 4.2857 |
| 15 | 1.57080 | 0.25 | 90 | 4 |
| 16 | 1.67552 | 0.2667 | 96 | 3.75 |
| 17 | 1.78024 | 0.2833 | 102 | 3.5294 |
| 18 | 1.88496 | 0.3 | 108 | 3.3333 |
| 19 | 1.98968 | 0.3167 | 114 | 3.1579 |
| 20 | 2.09440 | 0.3333 | 120 | 3 |
| 21 | 2.19911 | 0.35 | 126 | 2.8571 |
| 22 | 2.30383 | 0.3667 | 132 | 2.7273 |
| 23 | 2.40855 | 0.3833 | 138 | 2.6087 |
| 24 | 2.51327 | 0.4 | 144 | 2.5 |
| 25 | 2.61799 | 0.4167 | 150 | 2.4 |
| 26 | 2.72271 | 0.4333 | 156 | 2.3077 |
| 27 | 2.82743 | 0.45 | 162 | 2.2222 |
| 28 | 2.93215 | 0.4667 | 168 | 2.1429 |
| 29 | 3.03687 | 0.4833 | 174 | 2.069 |
| 30 | 3.14159 | 0.5 | 180 | 2 |
| 31 | 3.24631 | 0.5167 | 186 | 1.9355 |
| 32 | 3.35103 | 0.5333 | 192 | 1.875 |
| 33 | 3.45575 | 0.55 | 198 | 1.8182 |
| 34 | 3.56047 | 0.5667 | 204 | 1.7647 |
| 35 | 3.66519 | 0.5833 | 210 | 1.7143 |
| 36 | 3.76991 | 0.6 | 216 | 1.6667 |
| 37 | 3.87463 | 0.6167 | 222 | 1.6216 |
| 38 | 3.97935 | 0.6333 | 228 | 1.5789 |
| 39 | 4.08407 | 0.65 | 234 | 1.5385 |
| 40 | 4.18879 | 0.6667 | 240 | 1.5 |
| 41 | 4.29351 | 0.6833 | 246 | 1.4634 |
| 42 | 4.39823 | 0.7 | 252 | 1.4286 |
| 43 | 4.50295 | 0.7167 | 258 | 1.3953 |
| 44 | 4.60767 | 0.7333 | 264 | 1.3636 |
| 45 | 4.71239 | 0.75 | 270 | 1.3333 |
| 46 | 4.81711 | 0.7667 | 276 | 1.3043 |
| 47 | 4.92183 | 0.7833 | 282 | 1.2766 |
| 48 | 5.02655 | 0.8 | 288 | 1.25 |
| 49 | 5.13127 | 0.8167 | 294 | 1.2245 |
| 50 | 5.23599 | 0.8333 | 300 | 1.2 |
| 51 | 5.34071 | 0.85 | 306 | 1.1765 |
| 52 | 5.44543 | 0.8667 | 312 | 1.1538 |
| 53 | 5.55015 | 0.8833 | 318 | 1.1321 |
| 54 | 5.65487 | 0.9 | 324 | 1.1111 |
| 55 | 5.75959 | 0.9167 | 330 | 1.0909 |
| 56 | 5.86431 | 0.9333 | 336 | 1.0714 |
| 57 | 5.96903 | 0.95 | 342 | 1.0526 |
| 58 | 6.07375 | 0.9667 | 348 | 1.0345 |
| 59 | 6.17847 | 0.9833 | 354 | 1.0169 |
| 60 | 6.28319 | 1 | 360 | 1 |
| 61 | 6.38791 | 1.0167 | 366 | 0.9836 |
| 62 | 6.49262 | 1.0333 | 372 | 0.9677 |
| 63 | 6.59734 | 1.05 | 378 | 0.9524 |
| 64 | 6.70206 | 1.0667 | 384 | 0.9375 |
| 65 | 6.80678 | 1.0833 | 390 | 0.9231 |
| 66 | 6.91150 | 1.1 | 396 | 0.9091 |
| 67 | 7.01622 | 1.1167 | 402 | 0.8955 |
| 68 | 7.12094 | 1.1333 | 408 | 0.8824 |
| 69 | 7.22566 | 1.15 | 414 | 0.8696 |
| 70 | 7.33038 | 1.1667 | 420 | 0.8571 |
| 71 | 7.43510 | 1.1833 | 426 | 0.8451 |
| 72 | 7.53982 | 1.2 | 432 | 0.8333 |
| 73 | 7.64454 | 1.2167 | 438 | 0.8219 |
| 74 | 7.74926 | 1.2333 | 444 | 0.8108 |
| 75 | 7.85398 | 1.25 | 450 | 0.8 |
| 76 | 7.95870 | 1.2667 | 456 | 0.7895 |
| 77 | 8.06342 | 1.2833 | 462 | 0.7792 |
| 78 | 8.16814 | 1.3 | 468 | 0.7692 |
| 79 | 8.27286 | 1.3167 | 474 | 0.7595 |
| 80 | 8.37758 | 1.3333 | 480 | 0.75 |
| 81 | 8.48230 | 1.35 | 486 | 0.7407 |
| 82 | 8.58702 | 1.3667 | 492 | 0.7317 |
| 83 | 8.69174 | 1.3833 | 498 | 0.7229 |
| 84 | 8.79646 | 1.4 | 504 | 0.7143 |
| 85 | 8.90118 | 1.4167 | 510 | 0.7059 |
| 86 | 9.00590 | 1.4333 | 516 | 0.6977 |
| 87 | 9.11062 | 1.45 | 522 | 0.6897 |
| 88 | 9.21534 | 1.4667 | 528 | 0.6818 |
| 89 | 9.32006 | 1.4833 | 534 | 0.6742 |
| 90 | 9.42478 | 1.5 | 540 | 0.6667 |
| 91 | 9.52950 | 1.5167 | 546 | 0.6593 |
| 92 | 9.63422 | 1.5333 | 552 | 0.6522 |
| 93 | 9.73894 | 1.55 | 558 | 0.6452 |
| 94 | 9.84366 | 1.5667 | 564 | 0.6383 |
| 95 | 9.94838 | 1.5833 | 570 | 0.6316 |
| 96 | 10.05310 | 1.6 | 576 | 0.625 |
| 97 | 10.15782 | 1.6167 | 582 | 0.6186 |
| 98 | 10.26254 | 1.6333 | 588 | 0.6122 |
| 99 | 10.36726 | 1.65 | 594 | 0.6061 |
| 100 | 10.47198 | 1.6667 | 600 | 0.6 |
| 120 | 12.56637 | 2 | 720 | 0.5 |
| 180 | 18.84956 | 3 | 1,080 | 0.3333 |
| 200 | 20.94395 | 3.3333 | 1,200 | 0.3 |
| 300 | 31.41593 | 5 | 1,800 | 0.2 |
| 500 | 52.35988 | 8.3333 | 3,000 | 0.12 |
| 600 | 62.83185 | 10 | 3,600 | 0.1 |
| 750 | 78.53982 | 12.5 | 4,500 | 0.08 |
| 900 | 94.24778 | 15 | 5,400 | 0.0667 |
| 1,000 | 104.71976 | 16.6667 | 6,000 | 0.06 |
| 1,200 | 125.66371 | 20 | 7,200 | 0.05 |
| 1,450 | 151.84364 | 24.1667 | 8,700 | 0.0414 |
| 1,500 | 157.07963 | 25 | 9,000 | 0.04 |
| 1,750 | 183.25957 | 29.1667 | 10,500 | 0.0343 |
| 1,800 | 188.49556 | 30 | 10,800 | 0.0333 |
| 2,400 | 251.32741 | 40 | 14,400 | 0.025 |
| 2,850 | 298.45130 | 47.5 | 17,100 | 0.0211 |
| 3,000 | 314.15927 | 50 | 18,000 | 0.02 |
| 3,450 | 361.28316 | 57.5 | 20,700 | 0.0174 |
| 3,600 | 376.99112 | 60 | 21,600 | 0.0167 |
| 5,000 | 523.59878 | 83.3333 | 30,000 | 0.012 |
| 5,400 | 565.48668 | 90 | 32,400 | 0.0111 |
| 7,200 | 753.98224 | 120 | 43,200 | 0.0083 |
| 10,000 | 1047.19755 | 166.6667 | 60,000 | 0.006 |
| 15,000 | 1570.79633 | 250 | 90,000 | 0.004 |
| 20,000 | 2094.39510 | 333.3333 | 120,000 | 0.003 |
Engineering & Applied Kinematics Specialists
Our engineering and editorial specialists build, review, and mathematically verify rotational kinematics tools and technical datasets against international SI metrology standards.
Master the rpm to radians per second conversion. Get the exact formula, avoid rounding errors, understand the calculus, and use our free calculator.
Read articleA practical guide to angular velocity. Learn what it is, how it differs from linear velocity, and why it is universally measured in radians per second.
Read articleStandard AC motor RPMs for 50Hz and 60Hz grids. Learn synchronous speed formulas, induction slip, and exact rad/s conversions for motor sizing.
Read articleTo convert 13 RPM to radians per second, multiply 13 by π and divide by 30: 13 × (π / 30) = 1.361357 rad/s (approx. 1.361 rad/s).
13 RPM equals 0.2167 Hz (revolutions per second), calculated by dividing 13 by 60 seconds.
To convert 1.361 rad/s back to RPM, multiply by 30 and divide by π: 1.361 × (30 / π) ≈ 13 RPM.
At 13 RPM, one full 360° revolution takes 4.6154 seconds (4615.38 ms).